CAMERA SENSOR
Get visual image signal.
Property
There are three sliders:
Horizontal resolution: the width of the output image's signalVertical resolution: the height of the output image's signalDefault FOV: the default FOV of the camera, i.e. no input signal
note
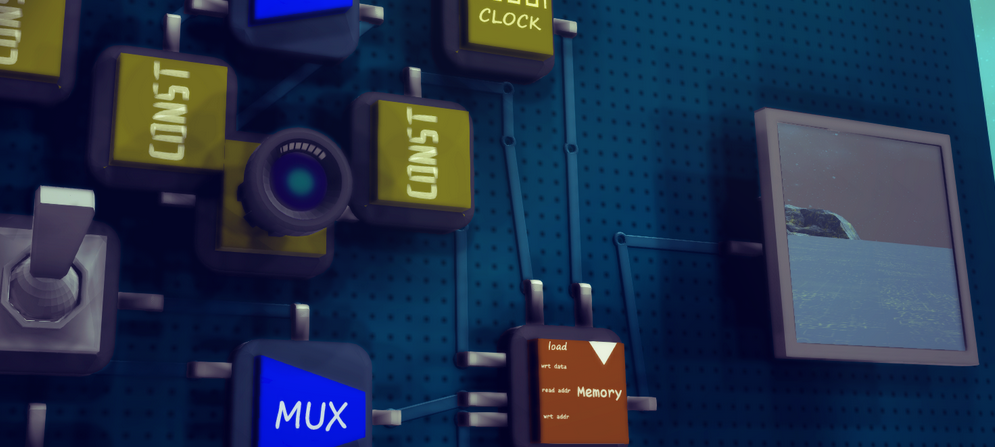 The white texture along the top edge of camera indicates what is upright to the image it will capture.
Input
The input signal should be float type. This input is used for adjusting the FOV(field of view) of the camera.
Output
The output's type is image, with the desired resolution.
warning
The far clip plane of the camera is 8000m, i.e. the camera can only see objects within 8000m.